ME134 team project with three collaborators
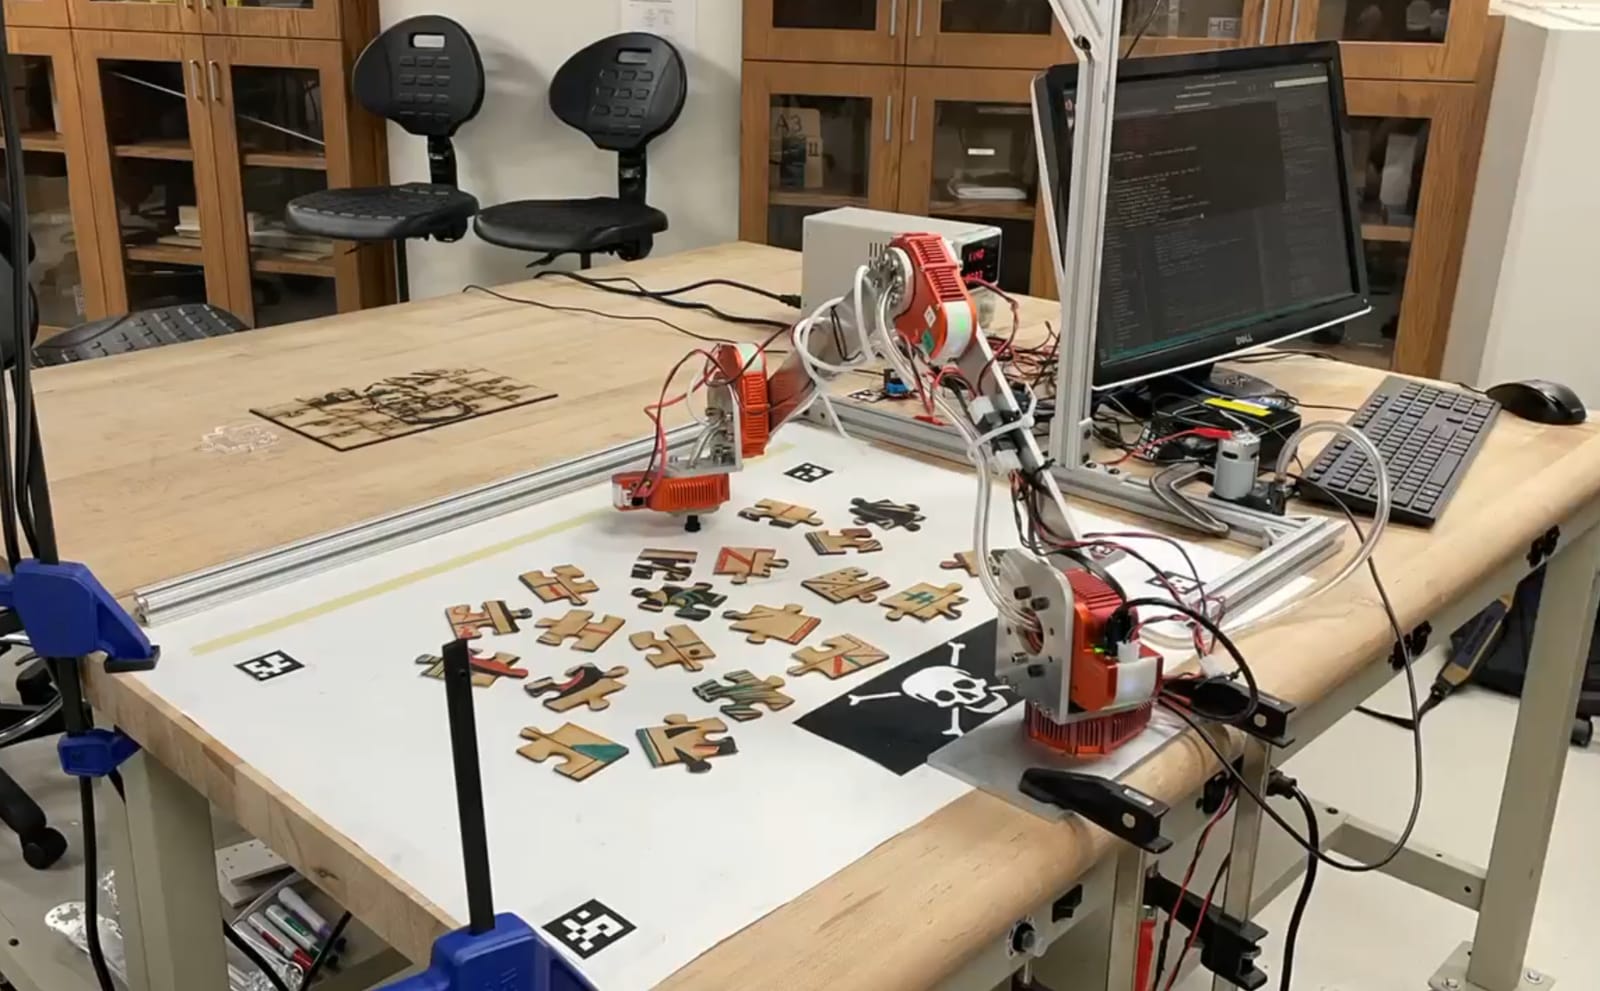
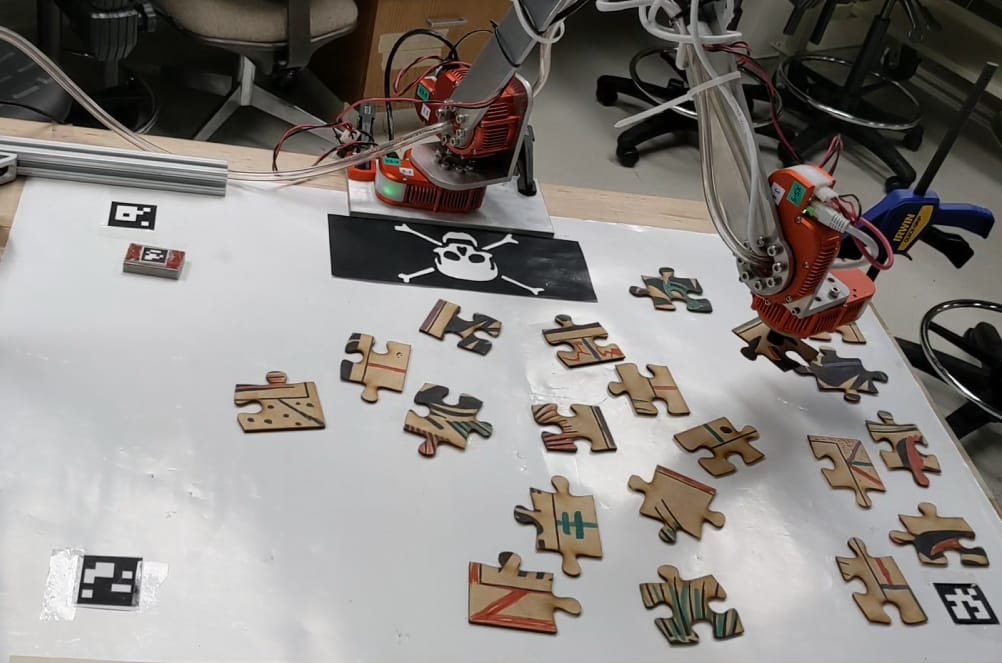
A five-axis robot arm that uses an overhead camera and vacuum gripper to solve a jigsaw puzzle.