Thomas Hayama
Applied AI & Robotics
I’m an applied AI engineer working on language-model applications, computer vision, and robotics.
I have 3+ years of experience building production software and prototypes, including systems for LiDAR perception and autonomous robots.
Projects
-
Puzzle Bot
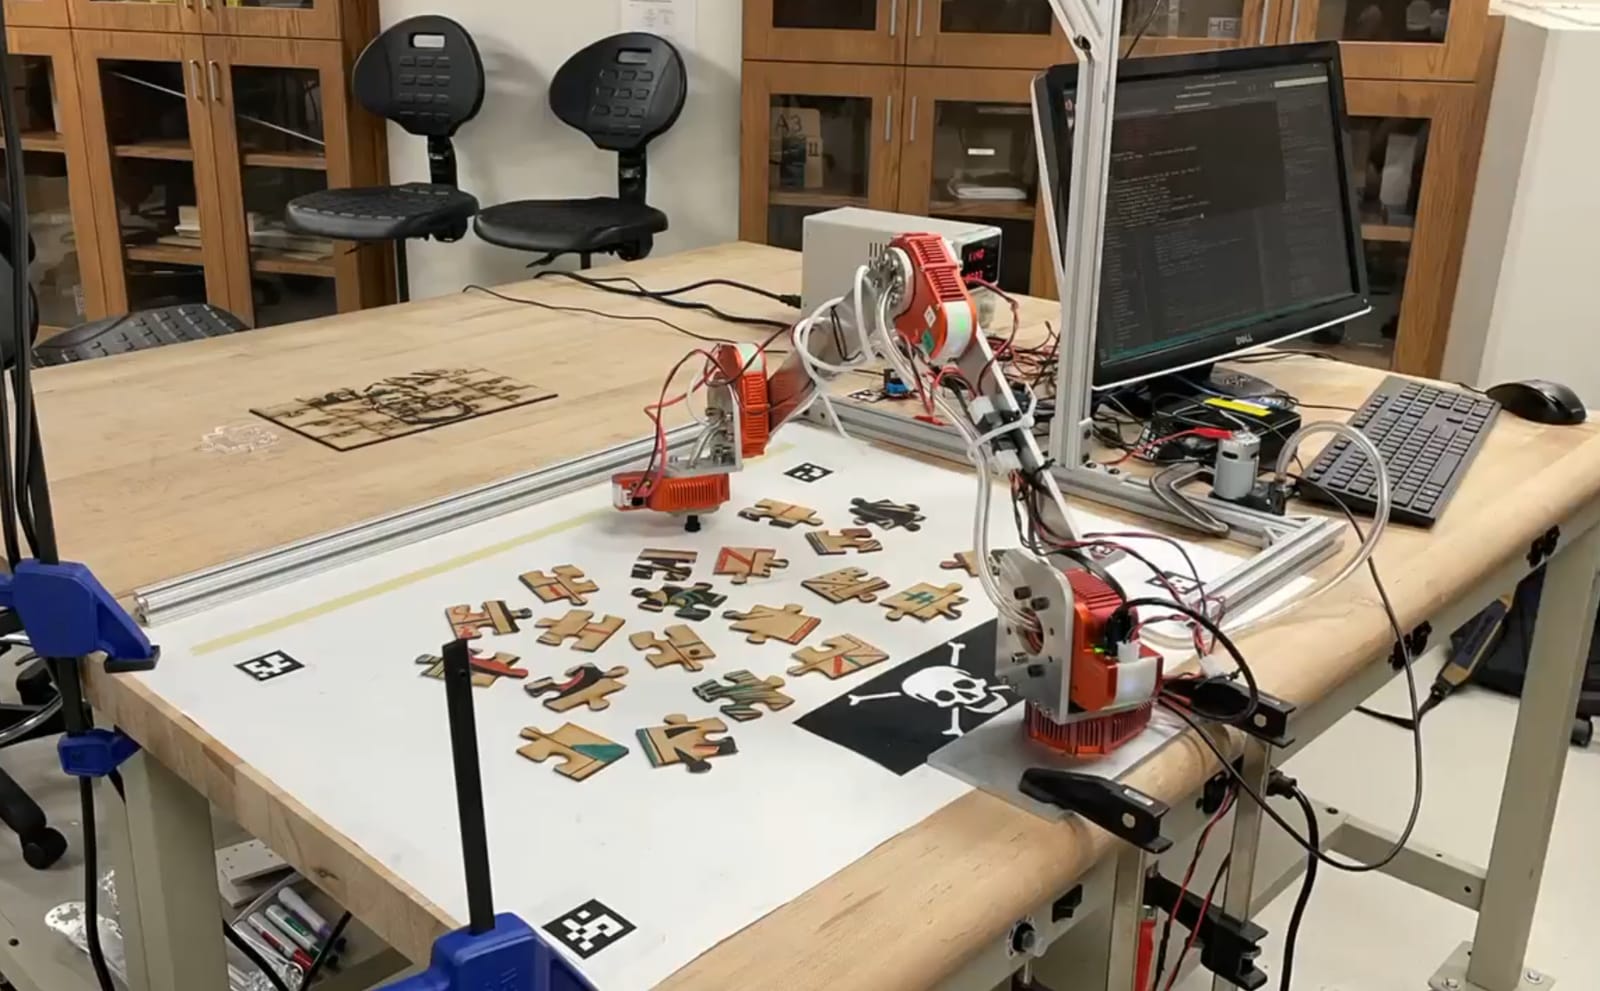
A five-axis arm that uses an overhead camera and vacuum gripper to solve a jigsaw puzzle.
View photos → -
SLAM Bot
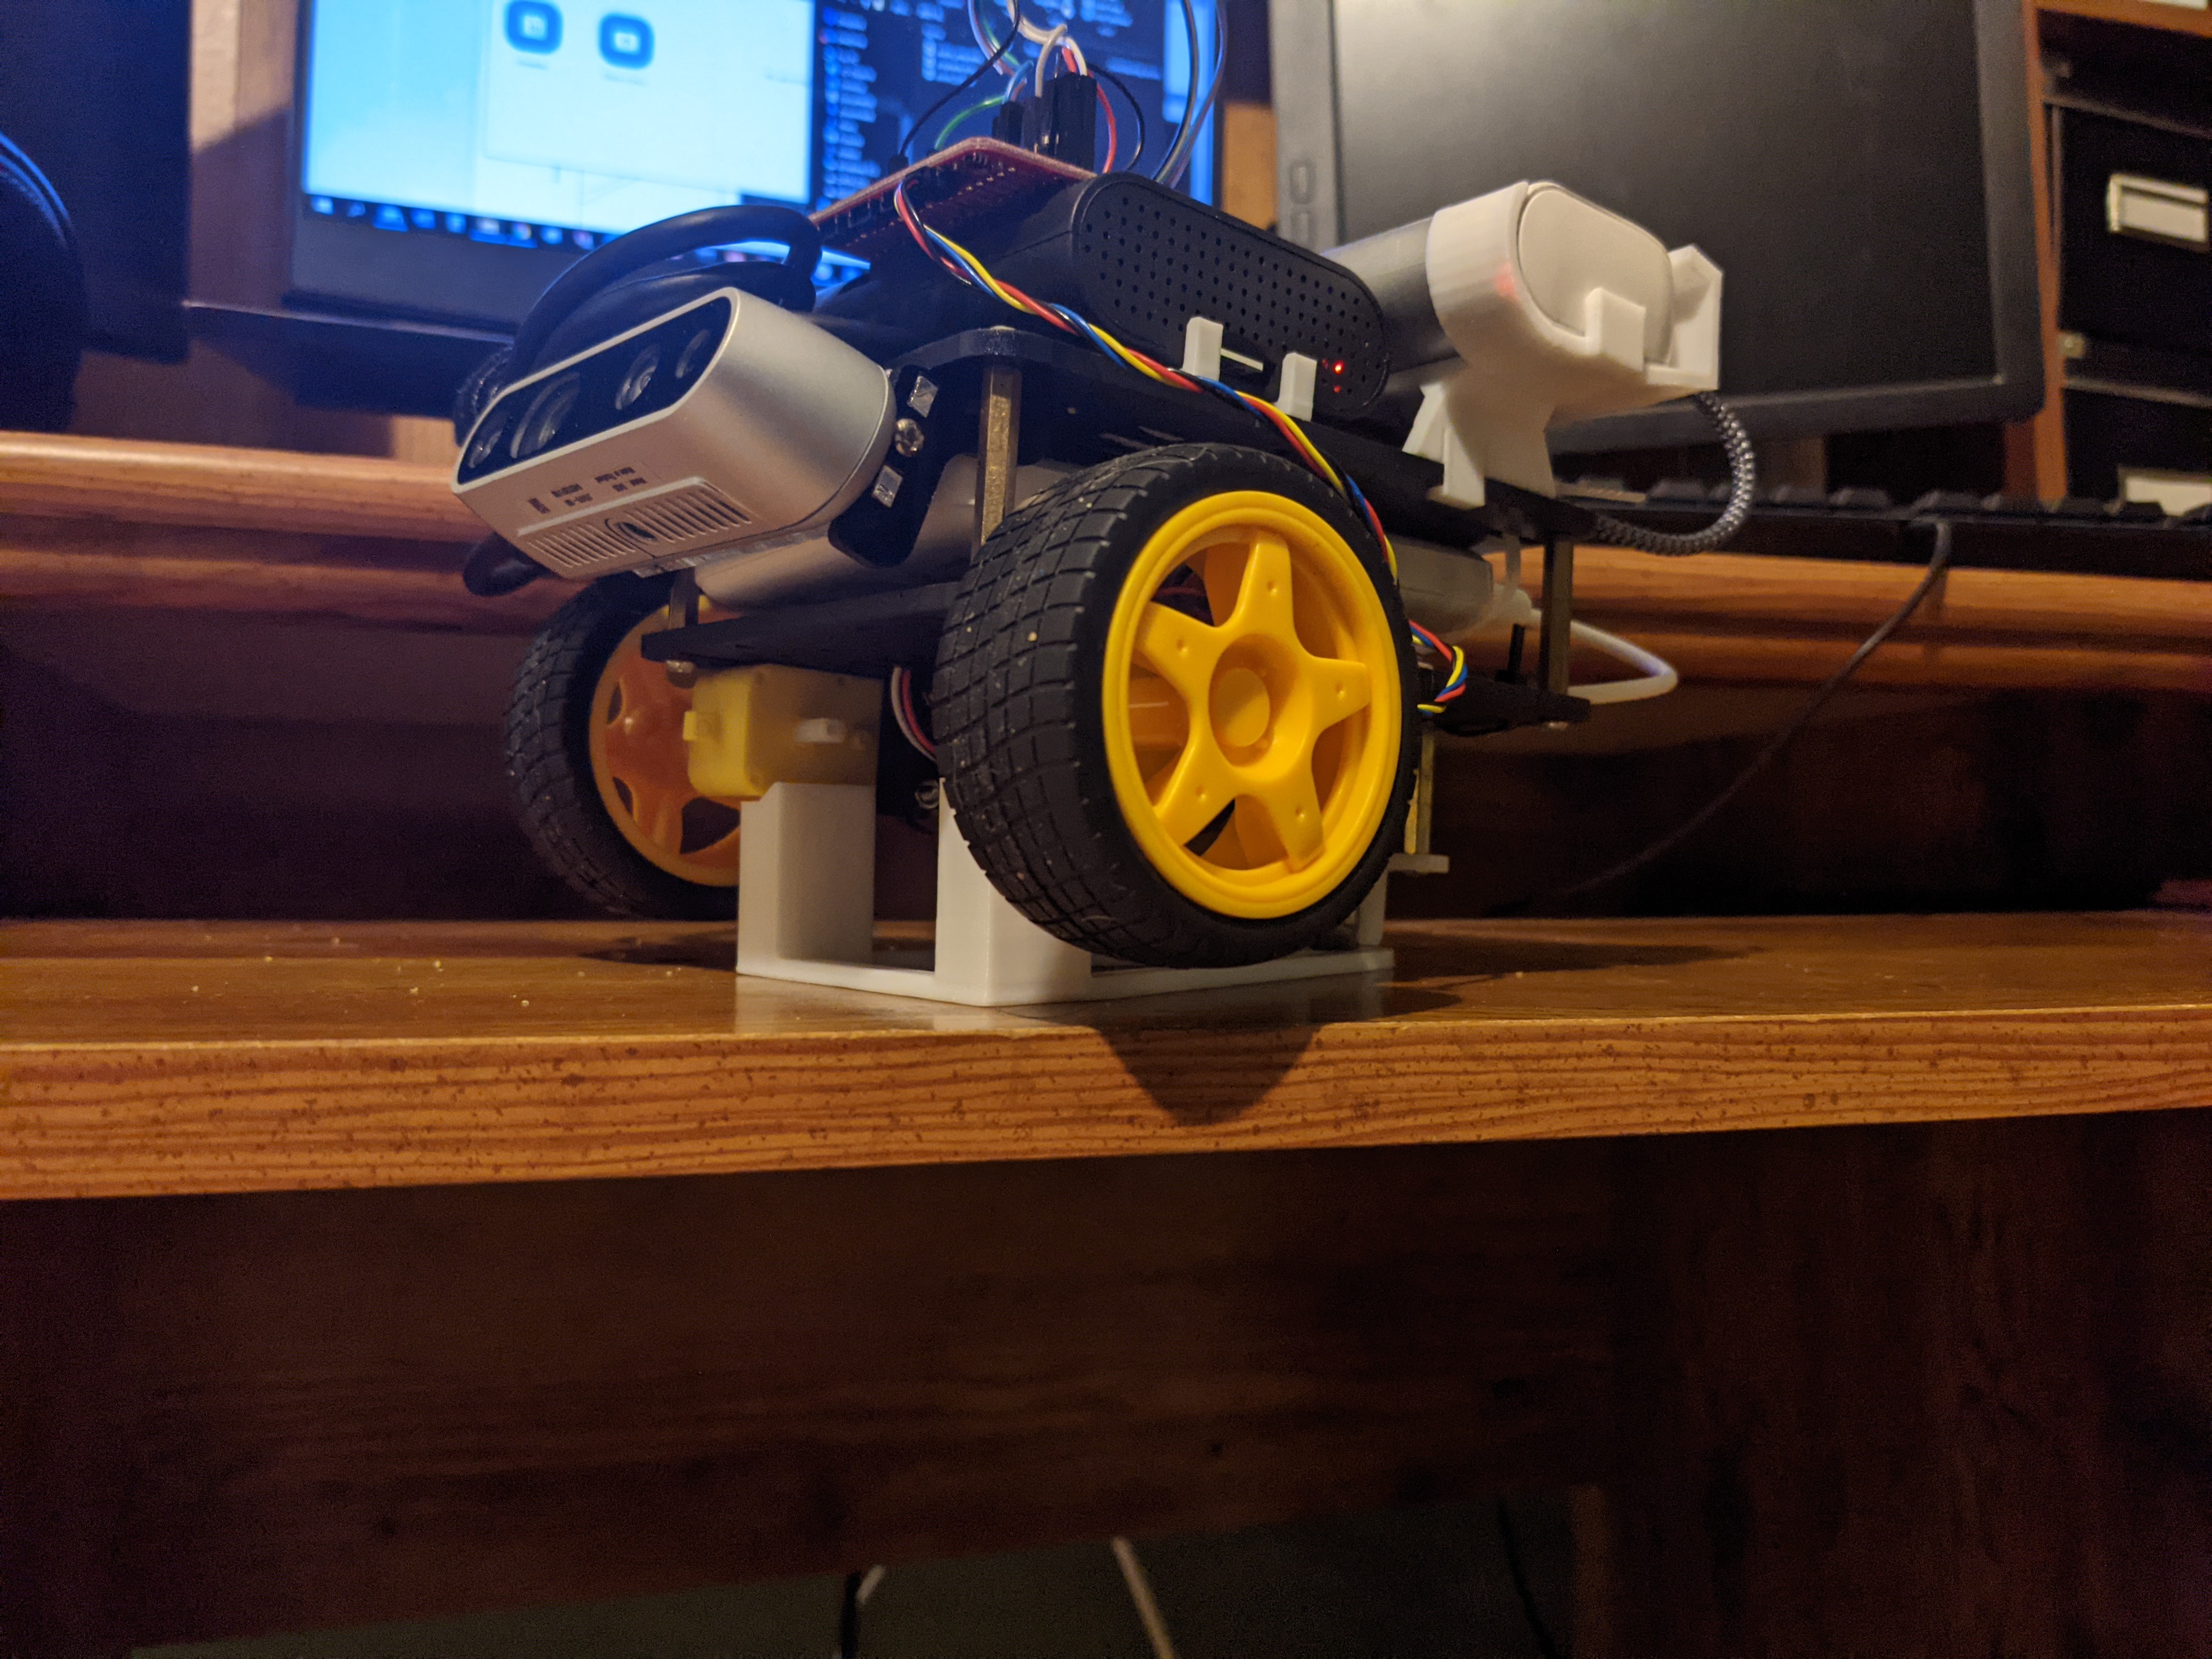
A two-wheeled robot that uses LiDAR to map its surroundings and estimate its position.
View photos →